ADAPT develops a sensorless variable-stiffness actuation and control framework for a knee exoskeleton, combining shape memory alloys, a variable-stiffness mechanism, physics-informed learning and AI-based real-time embedded control.
The mechanism
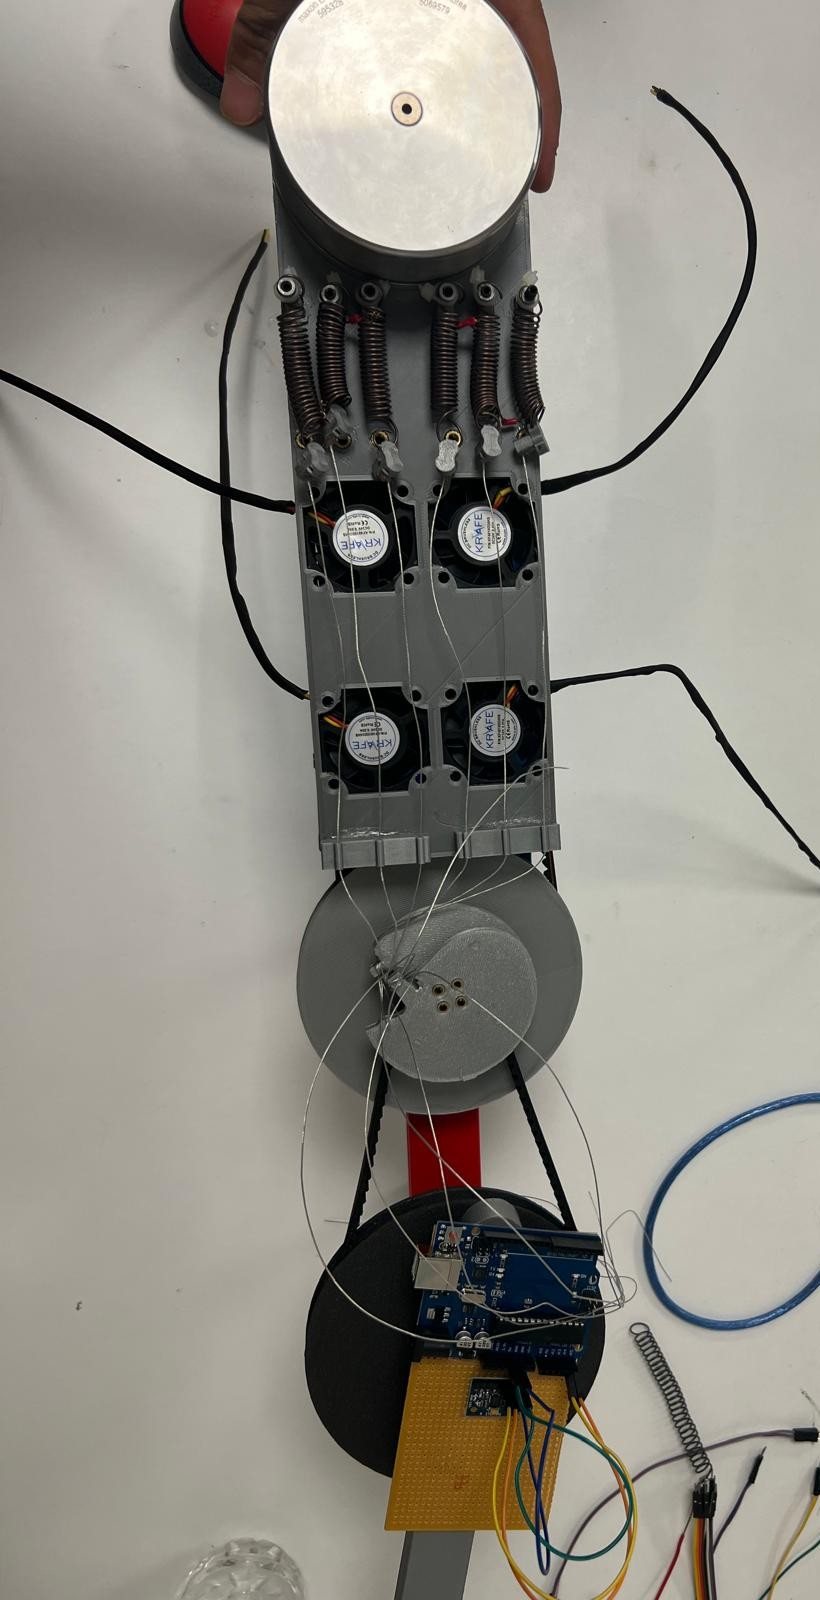
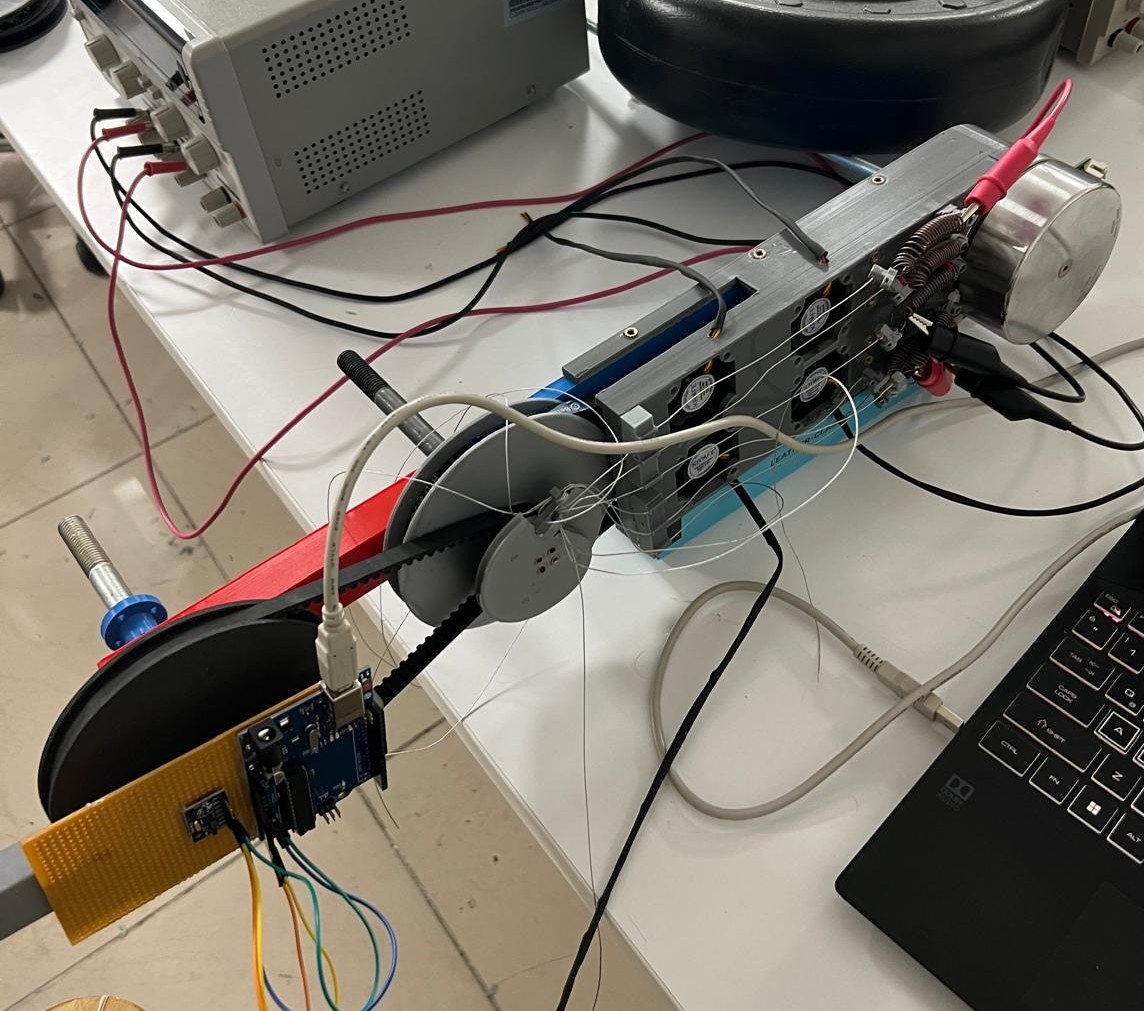
The core mechanical contribution is a variable stiffness actuator in which a BLDC motor provides the baseline actuation while antagonistically arranged SMA springs actively modify the actuator stiffness. This gives discrete or continuously adjustable stiffness without a second electric motor dedicated to stiffness regulation, which keeps the device compact and light enough to wear. Variable-radius pulleys shape the compliant torque reflected to the knee across the range of motion.
Sensorless estimation
A substantial part of the project is the experimental characterization of the SMA springs, used both to identify the thermal parameters of the physical model and to generate training and validation data. A Physics-Informed Neural Network estimates SMA temperature and martensitic phase fraction directly from measurable electrical and operating variables, with the SMA thermal energy-balance equation built into training so that physical constraints complement the data-driven model. Those estimates feed a force-estimation network, which means SMA force can be estimated without temperature or force sensors during normal operation.
Electronics and control
The project includes the complete actuation electronics: a dedicated current-control circuit regulating SMA current through a power MOSFET under high-frequency feedback control, with an independently controlled cooling fan managing the SMA cooling phase. The system integrates current measurement, electrical-resistance estimation, signal conditioning, multirate control, network inference, force estimation and supervisory heating and cooling control.
The exoskeleton is intended for rehabilitation and assistive use in passive, assistive and resistive modes, adapting its behaviour and mechanical stiffness to the rehabilitation task and to the interaction between the user and the device.
Gallery
Project team
Burak Elmas
Graduate Researcher
Variable-stiffness knee exoskeletons, shape-memory-alloy actuation and physics-informed control.
Omar Mahmoud Mohammad Khalil
Graduate Researcher
Knee exoskeleton design with variable-radius pulleys and shape-memory-alloy stiffness.