Active
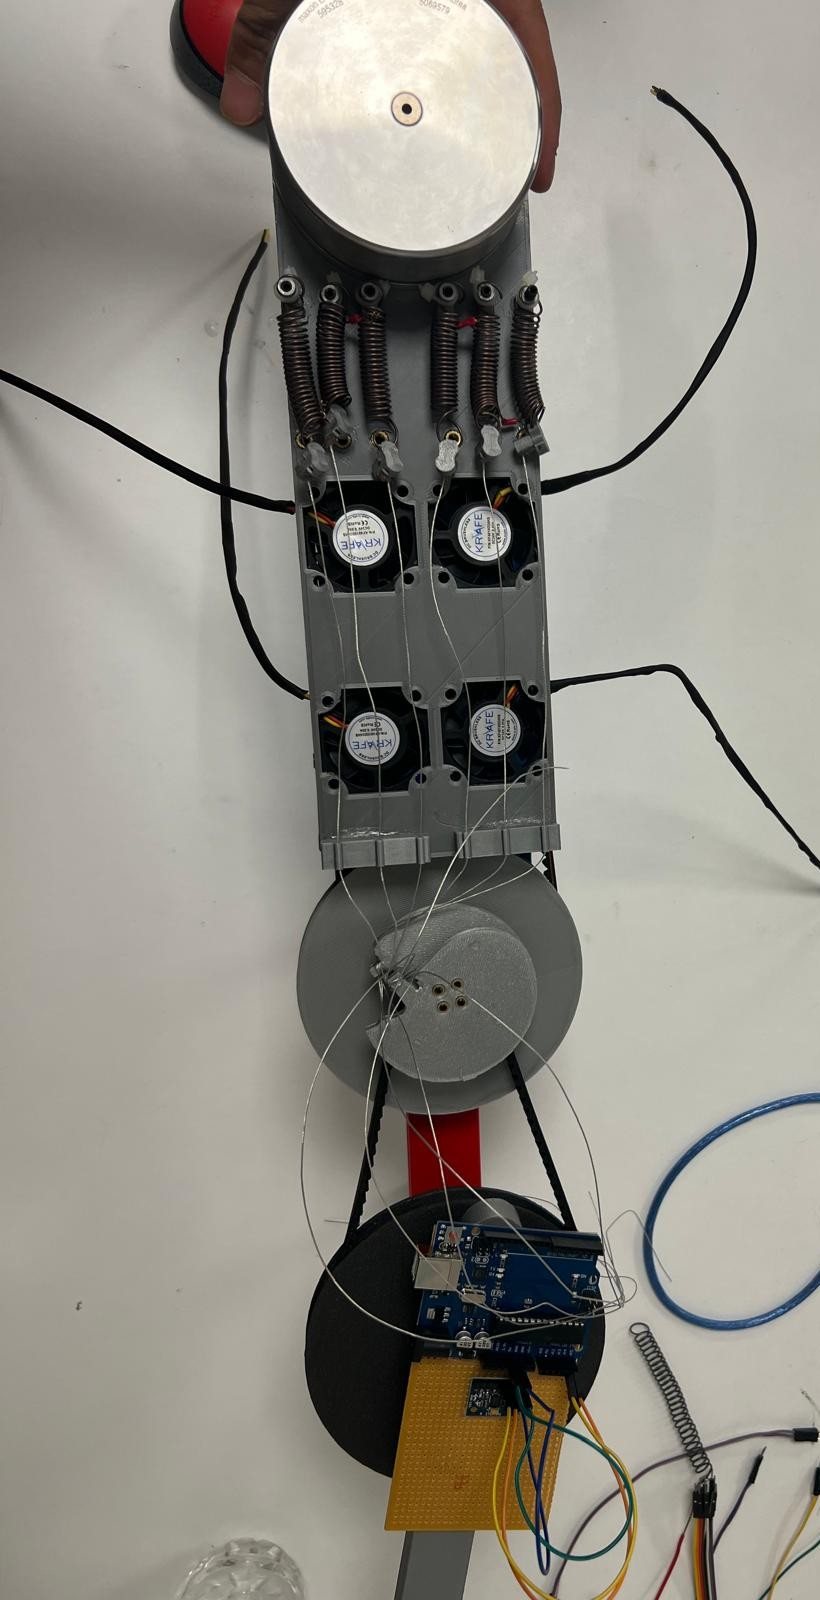
ADAPT: Variable-Stiffness Knee Exoskeleton
A powered knee exoskeleton combining variable-radius pulleys with shape-memory-alloy springs for controllable torque and stiffness, with sensorless force estimation.
We welcome doctoral, MSc and undergraduate researchersOpen positions
Burak Elmas is a graduate researcher working at the intersection of mechatronics, rehabilitation robotics, smart-material actuation and intelligent control. His research develops variable-stiffness knee exoskeletons driven by shape memory alloy (SMA) actuators, with particular emphasis on sensorless force estimation, physics-informed neural networks, real-time control and custom actuation electronics.
Design and control of a variable stiffness actuator. An electromechanical motor-driven actuator with an integrated transmission using SMA smart materials for adaptive stiffness, in which controlled thermal activation modifies the actuator’s mechanical response without a dedicated second stiffness motor. SMA characterization under varying pre-strain, current, loading, heating and forced-cooling conditions identifies the electro-thermo-mechanical behaviour.
Physics-informed neural network for sensorless SMA force control. A self-sensing framework estimating SMA force in real time without dedicated force or temperature sensors. The recurrent estimator combines current, electrical resistance, cooling state, operating time and actuator geometry with an embedded SMA thermal energy-balance model to estimate temperature and martensitic phase state, which then feed a recurrent force model.
Design and control of a variable stiffness knee exoskeleton. Motor-driven joint motion combined with an SMA stiffness mechanism and a variable-radius pulley transmission. Separating position actuation from stiffness modulation supports passive, assist-as-needed and resistive rehabilitation modes.
Programmable current controller card for SMA actuation. A closed-loop high-current controller for precise Joule heating of SMA actuators, using a linear-region power MOSFET, Hall-effect current feedback, PID regulation and gate protection to avoid the switching ripple of conventional PWM excitation.
A powered knee exoskeleton combining variable-radius pulleys with shape-memory-alloy springs for controllable torque and stiffness, with sensorless force estimation.