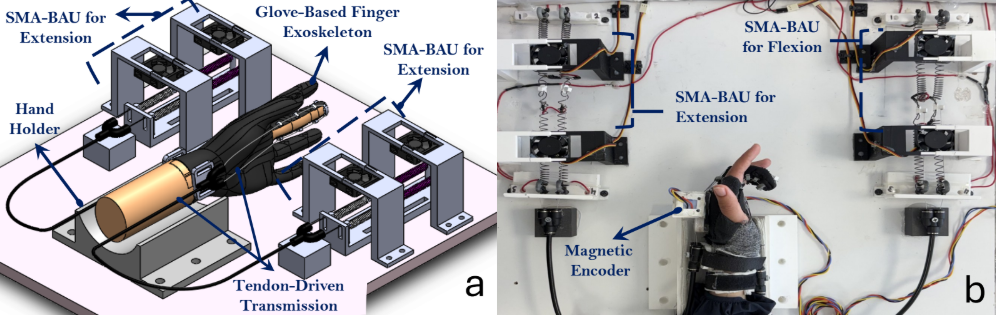
A wearable robot shares its workspace with a limb. Its mass, its stiffness and the directions in which it can move are not implementation details. They decide whether the device assists the movement or fights it.
Research topics
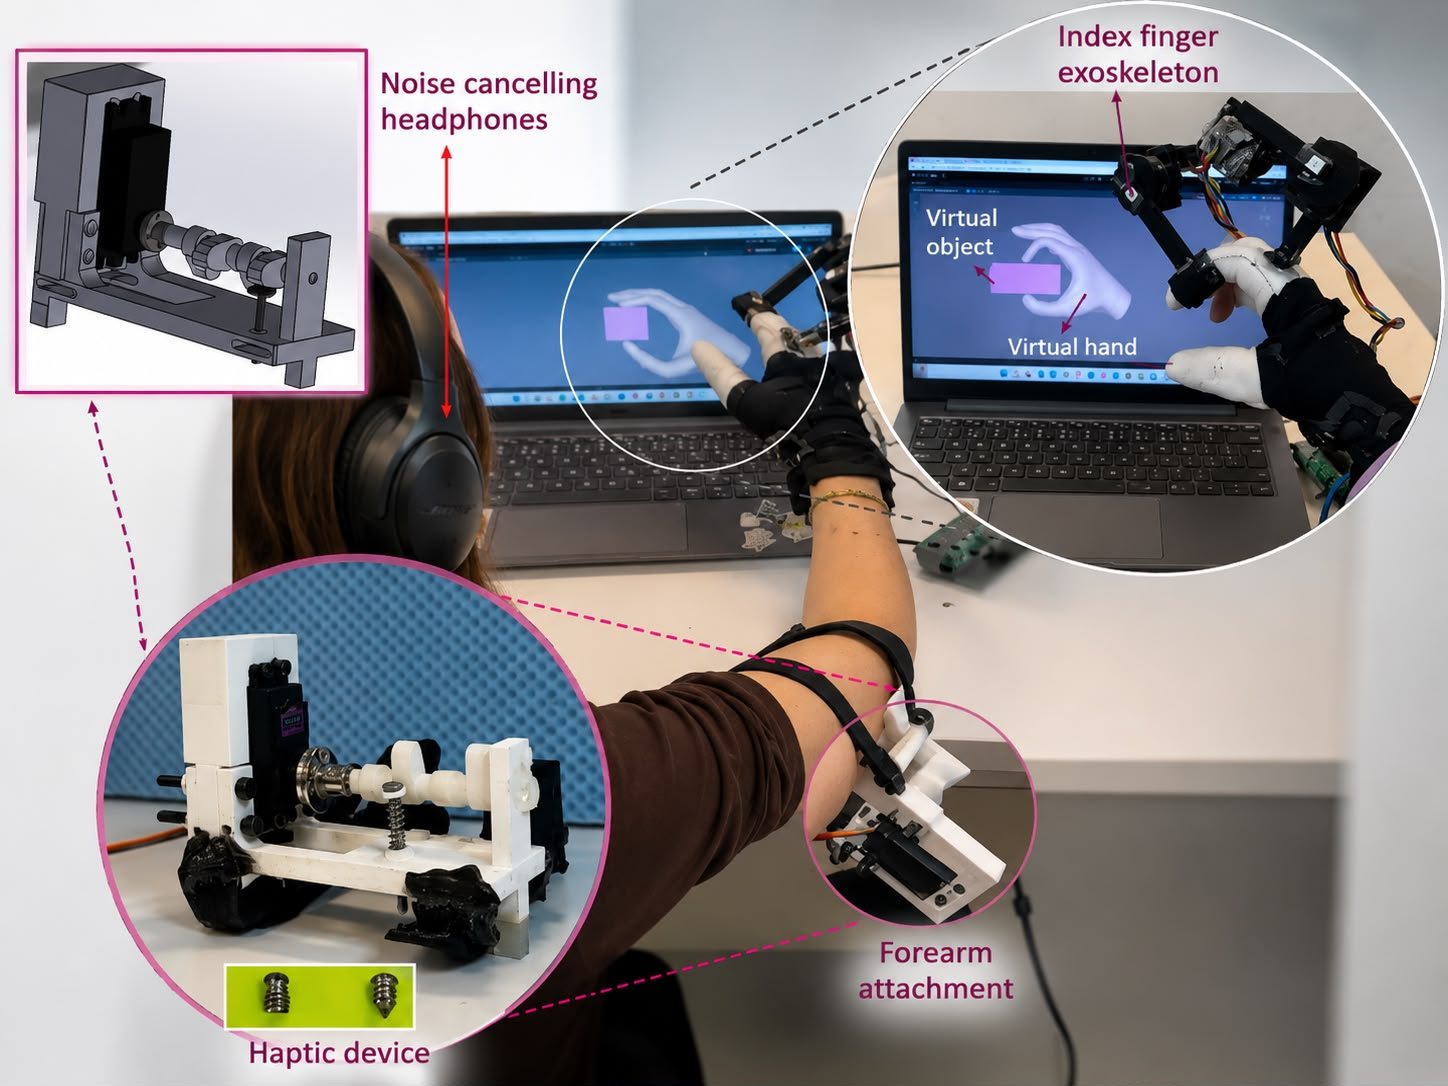
- Wearable robotic systems and exoskeletons
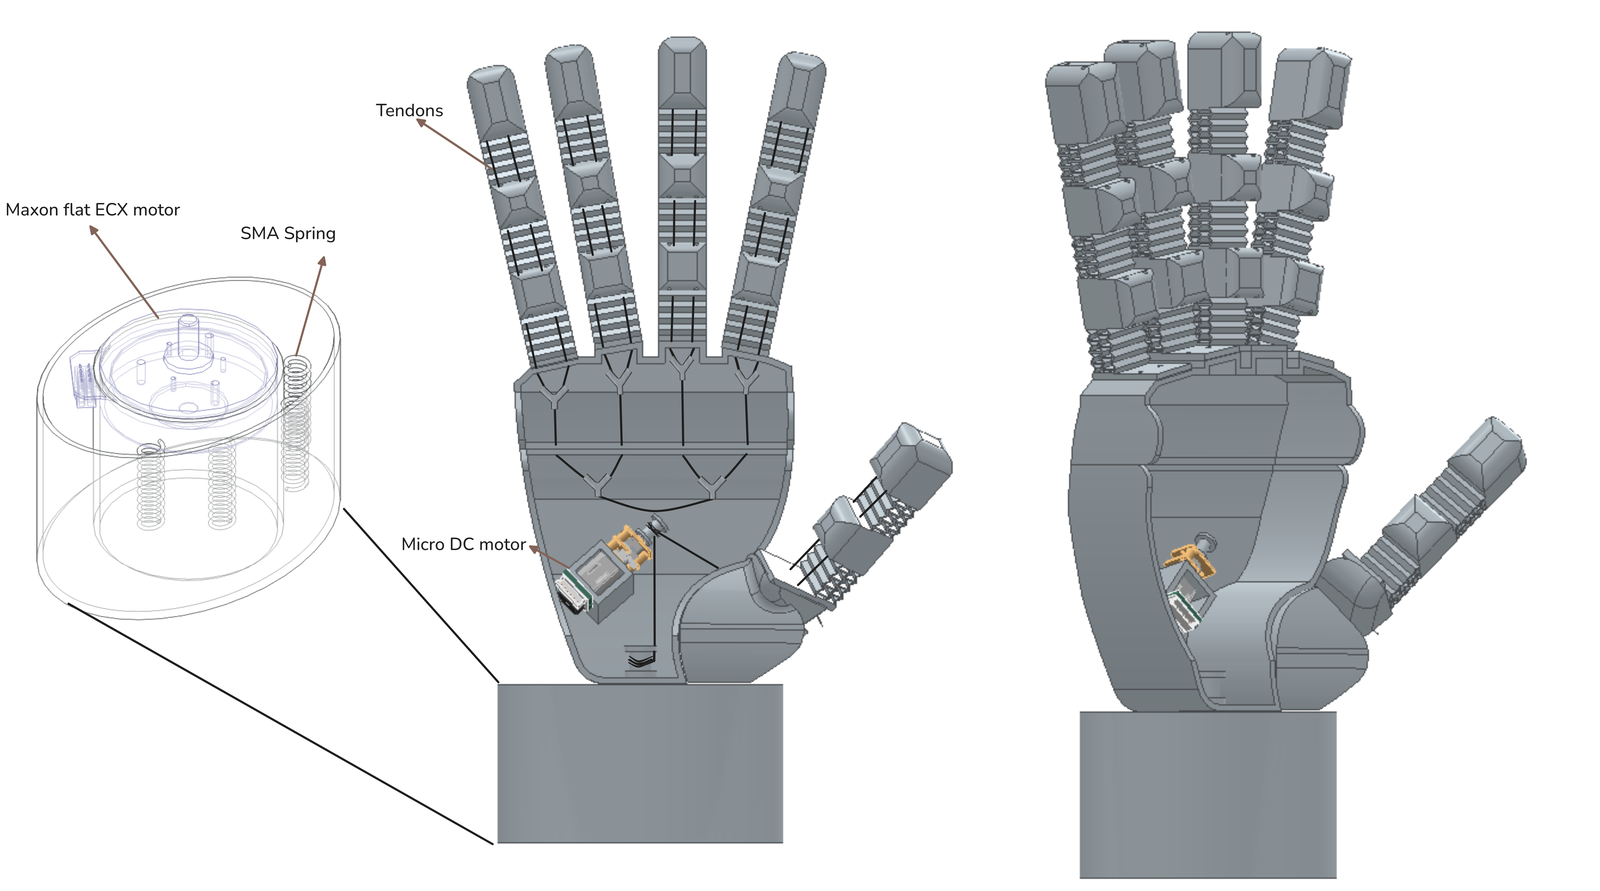
- Advanced prosthetic devices
- Underactuated and tendon-driven mechanisms
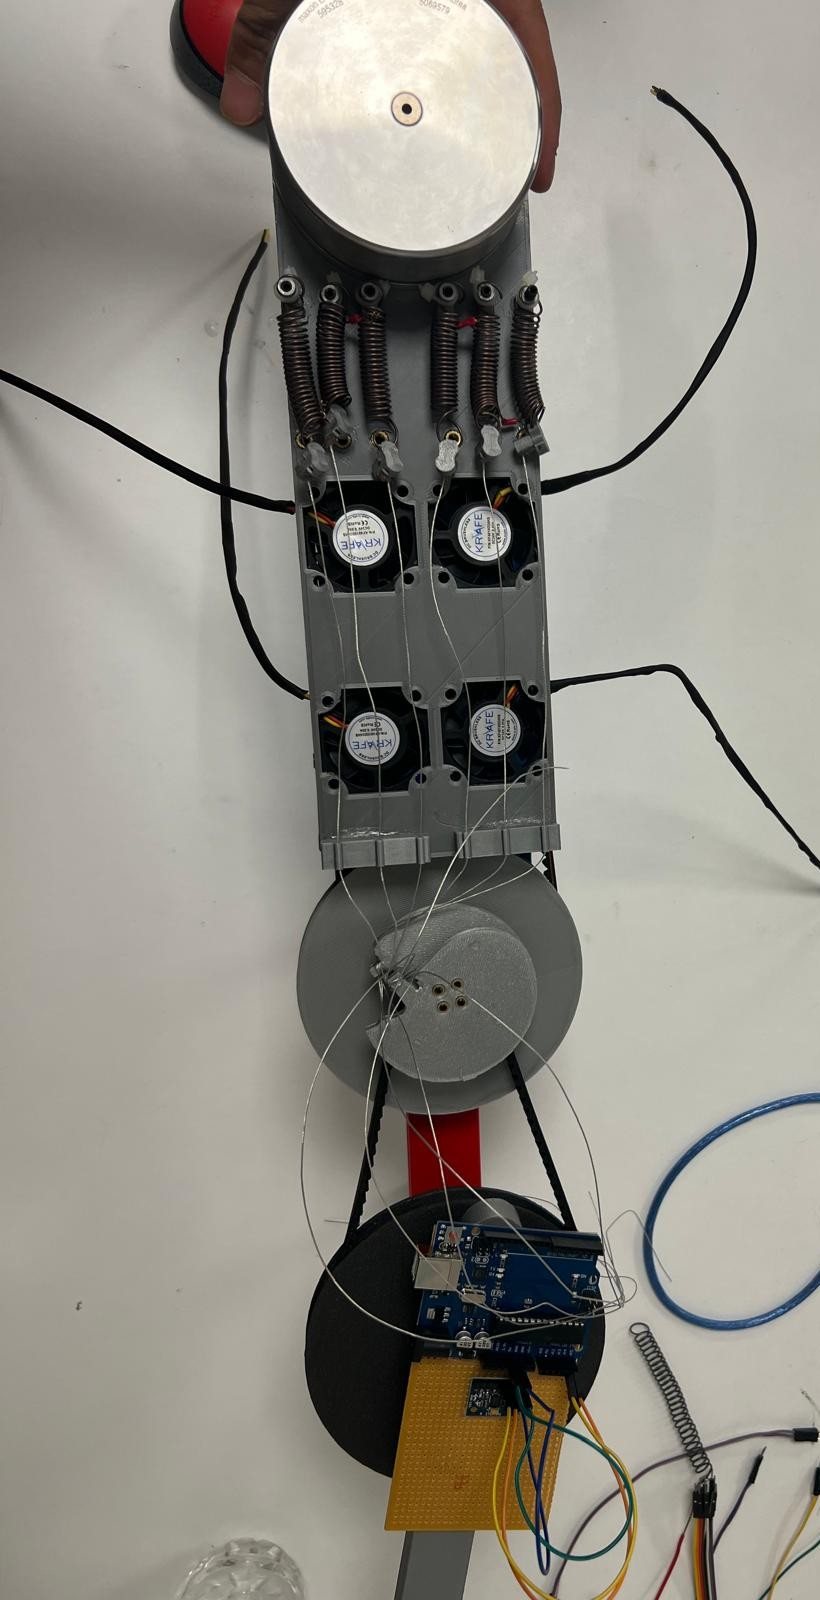
- Variable-stiffness actuation
- Smart materials in robotic design
- Human-inspired robotic design