Rehabilitation is not a single motion repeated to a fixed schedule. Recovery changes what the person can do from one session to the next, and a robot that cannot see that change cannot support it.
Research topics
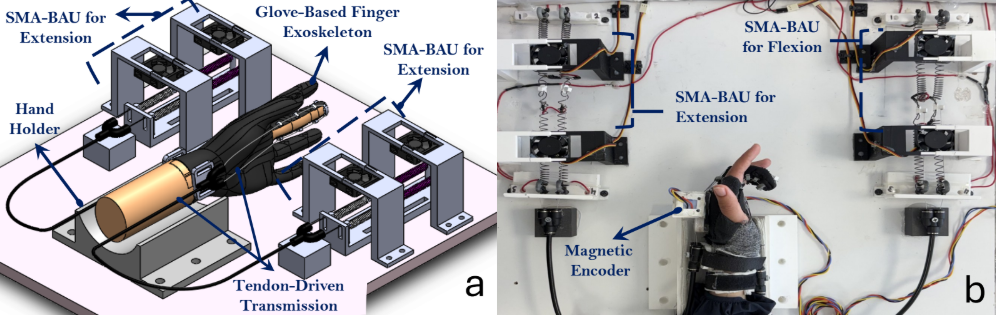
- Adaptive rehabilitation and assist-as-needed control
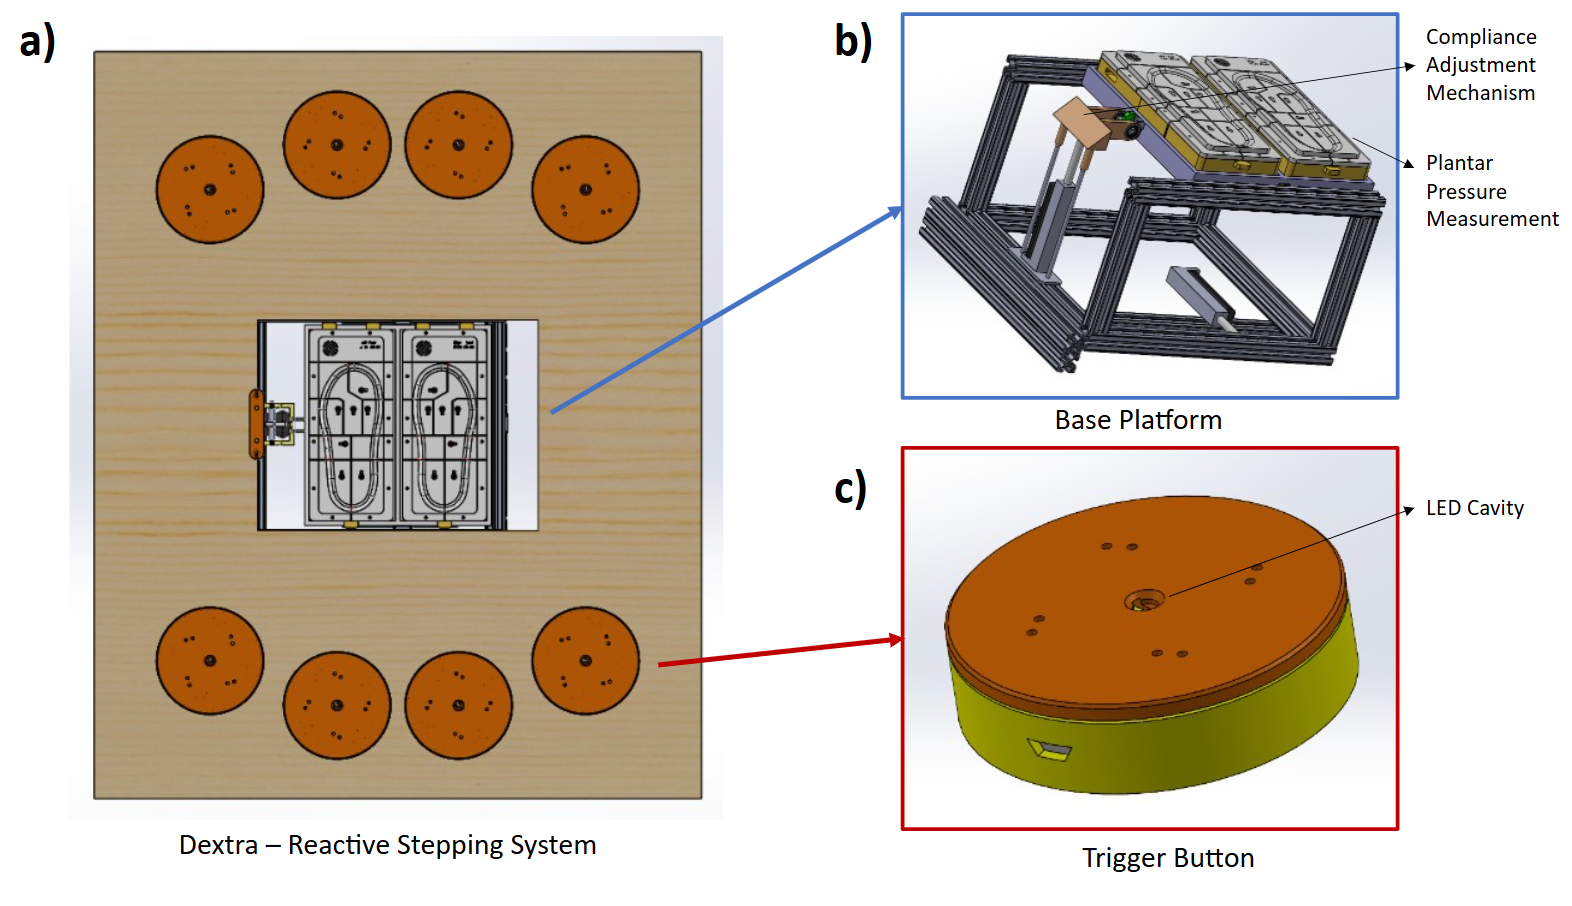
- Upper-limb and lower-limb rehabilitation systems
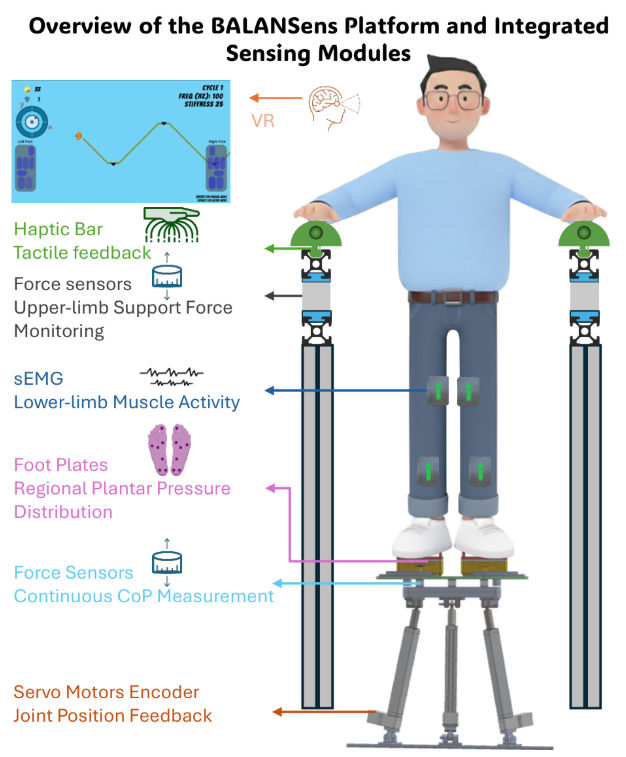
- Balance and motor training
- Biomechanical sensing during therapy
- Quantitative motor assessment and progress measurement
Working with the clinic
This work is carried out in close collaboration with clinicians and physiotherapists, which is what connects the engineering to real rehabilitation needs and to experimental evaluation with people.