Active
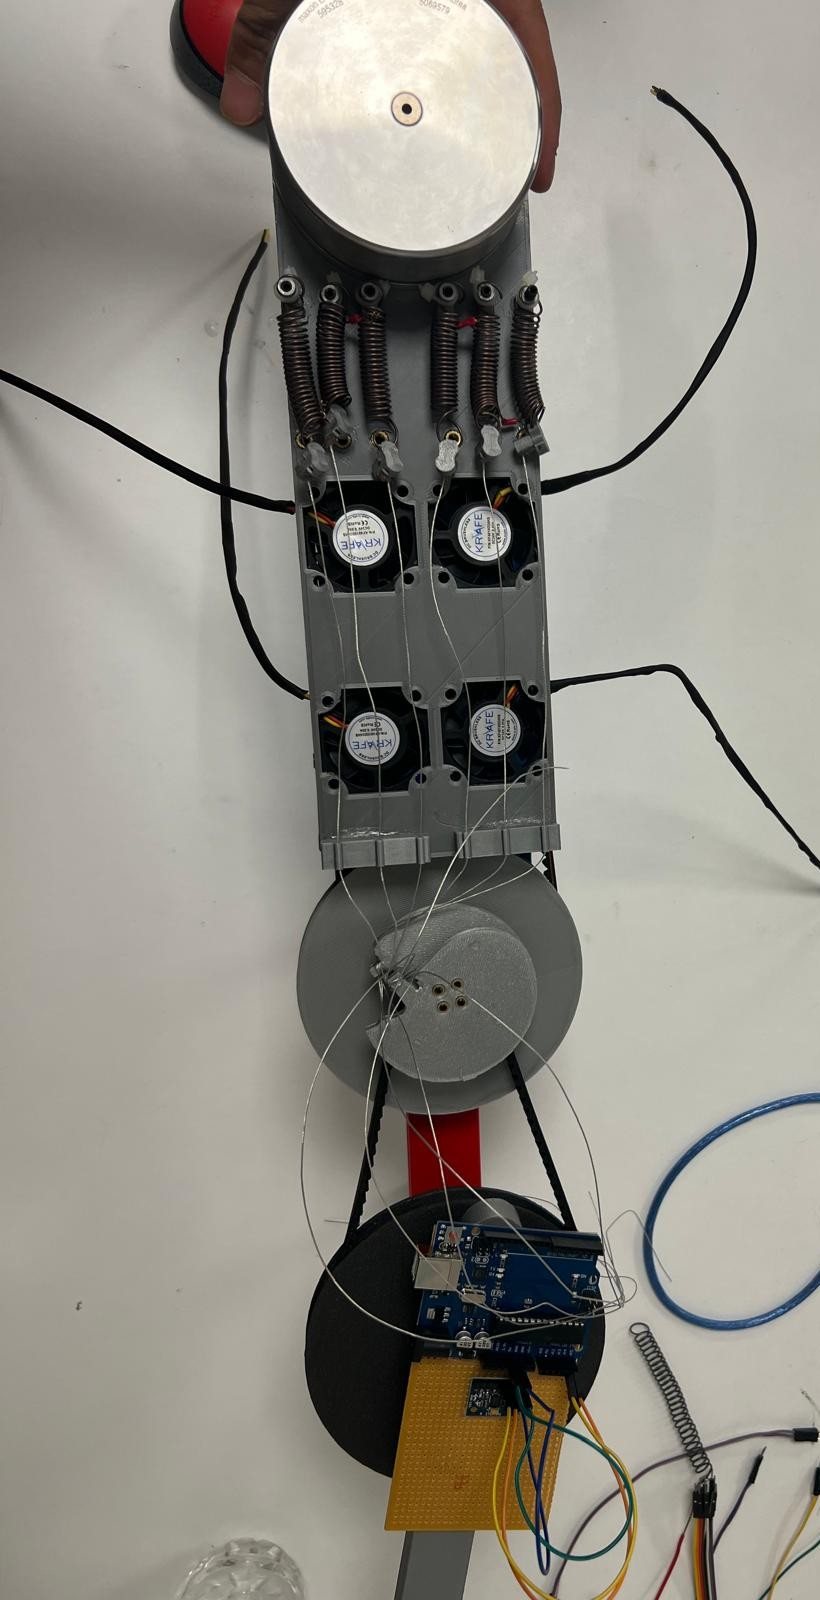
ADAPT: Variable-Stiffness Knee Exoskeleton
A powered knee exoskeleton combining variable-radius pulleys with shape-memory-alloy springs for controllable torque and stiffness, with sensorless force estimation.
We welcome doctoral, MSc and undergraduate researchersOpen positions
Omar Khalil is a biomedical engineer with hands-on experience in rehabilitation robotics, biomedical device development and clinical engineering practice. He designed and built a knee exoskeleton for rehabilitation as his graduation project while working in the Living Robotics Laboratory.
His project develops a powered knee exoskeleton that combines variable-radius pulleys with shape memory alloy springs to provide controllable knee torque and stiffness throughout the range of motion, establishing an experimentally grounded framework for the design and optimization of compact SMA-based assistive knee mechanisms.
A powered knee exoskeleton combining variable-radius pulleys with shape-memory-alloy springs for controllable torque and stiffness, with sensorless force estimation.