Active
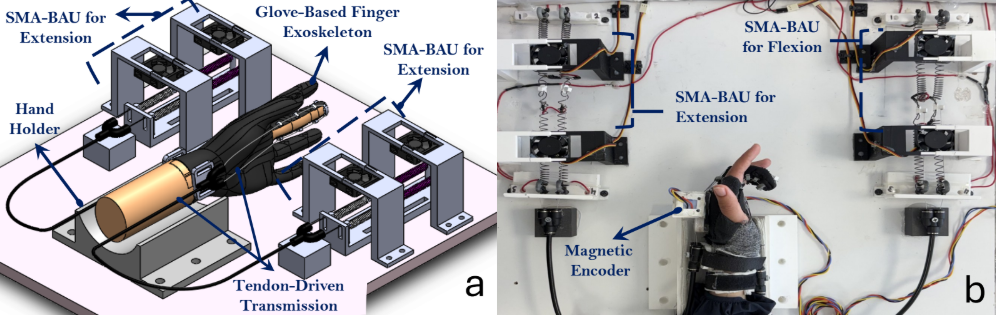
REACT: Rehabilitation Exoskeleton for Assisted Coordination of Tendon Therapy
A wearable finger exoskeleton using shape-memory-alloy actuation and tendon-driven transmission to deliver controlled, repeatable tendon therapy.
We welcome doctoral, MSc and undergraduate researchersOpen positions
Zikra Alfaris is an MSc student in Biomedical Engineering conducting research on wearable rehabilitation robotics in the Living Robotics Laboratory. She works on exoskeleton design, closed-loop control systems and human-participant experimentation, and is an author on a published IEEE conference paper.
Her work on REACT covers the design, modeling and experimental evaluation of a wearable SMA-actuated finger exoskeleton for passive tendon rehabilitation, including system prototyping, closed-loop control implementation in MATLAB/Simulink, and human-participant experiments with sEMG monitoring.
Poster presentation at the Turkish Robotics Conference 2026. Workshops: LITES 2025 and the SABITA Trends Workshop. Two patent applications are under review at the Turkish Patent and Trademark Office.
A wearable finger exoskeleton using shape-memory-alloy actuation and tendon-driven transmission to deliver controlled, repeatable tendon therapy.
H. Asran, Z. Alfaris & E. Hocaoglu
IEEE Medical Technologies Congress (TIPTEKNO)