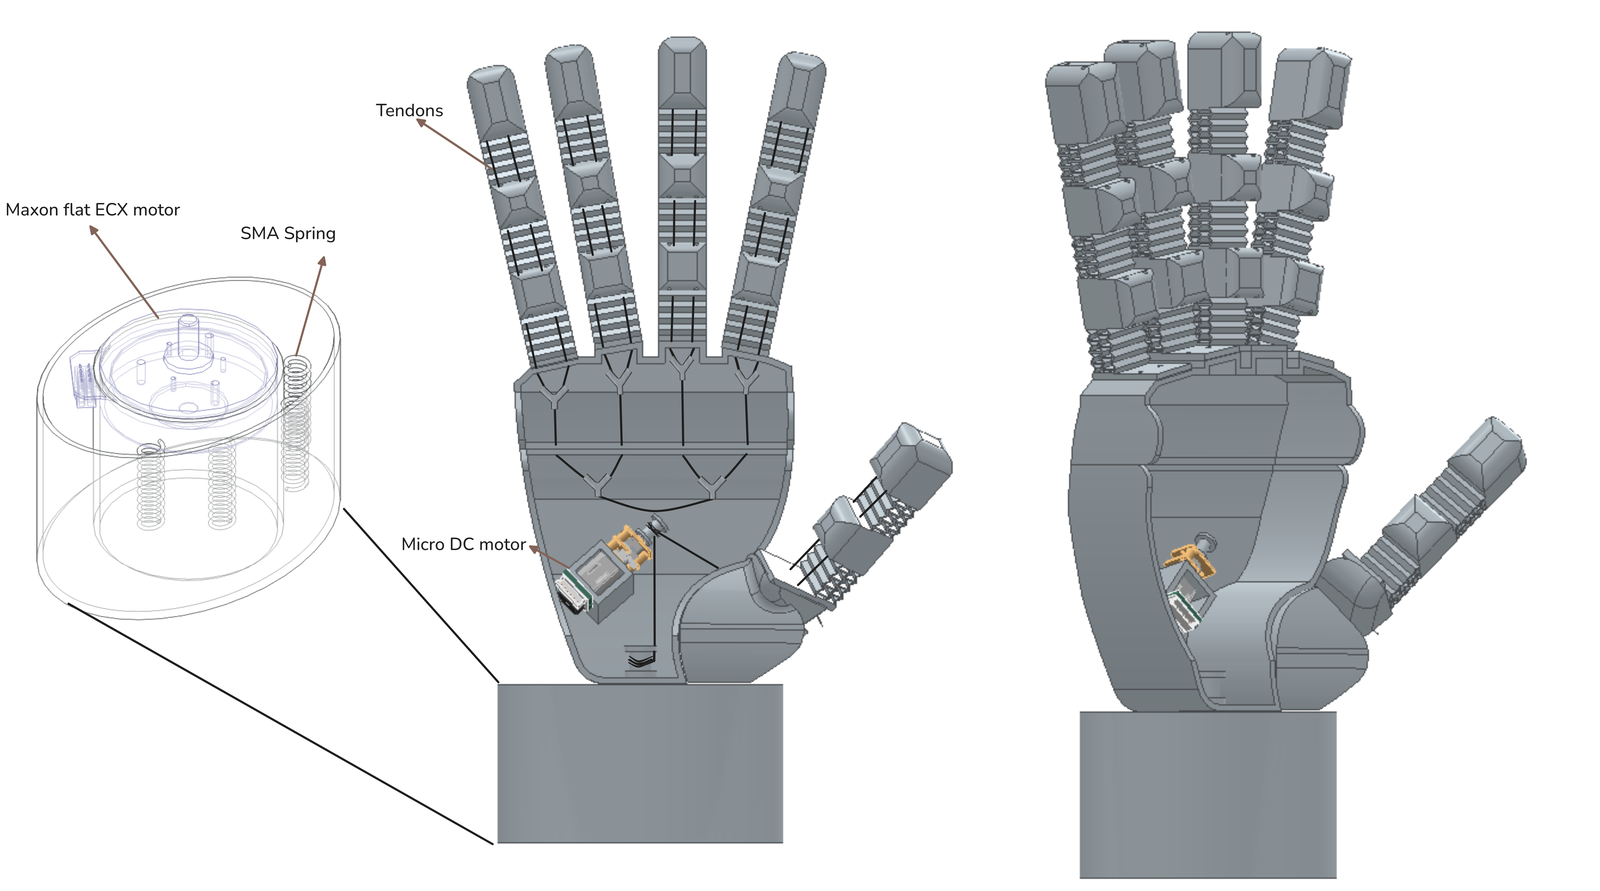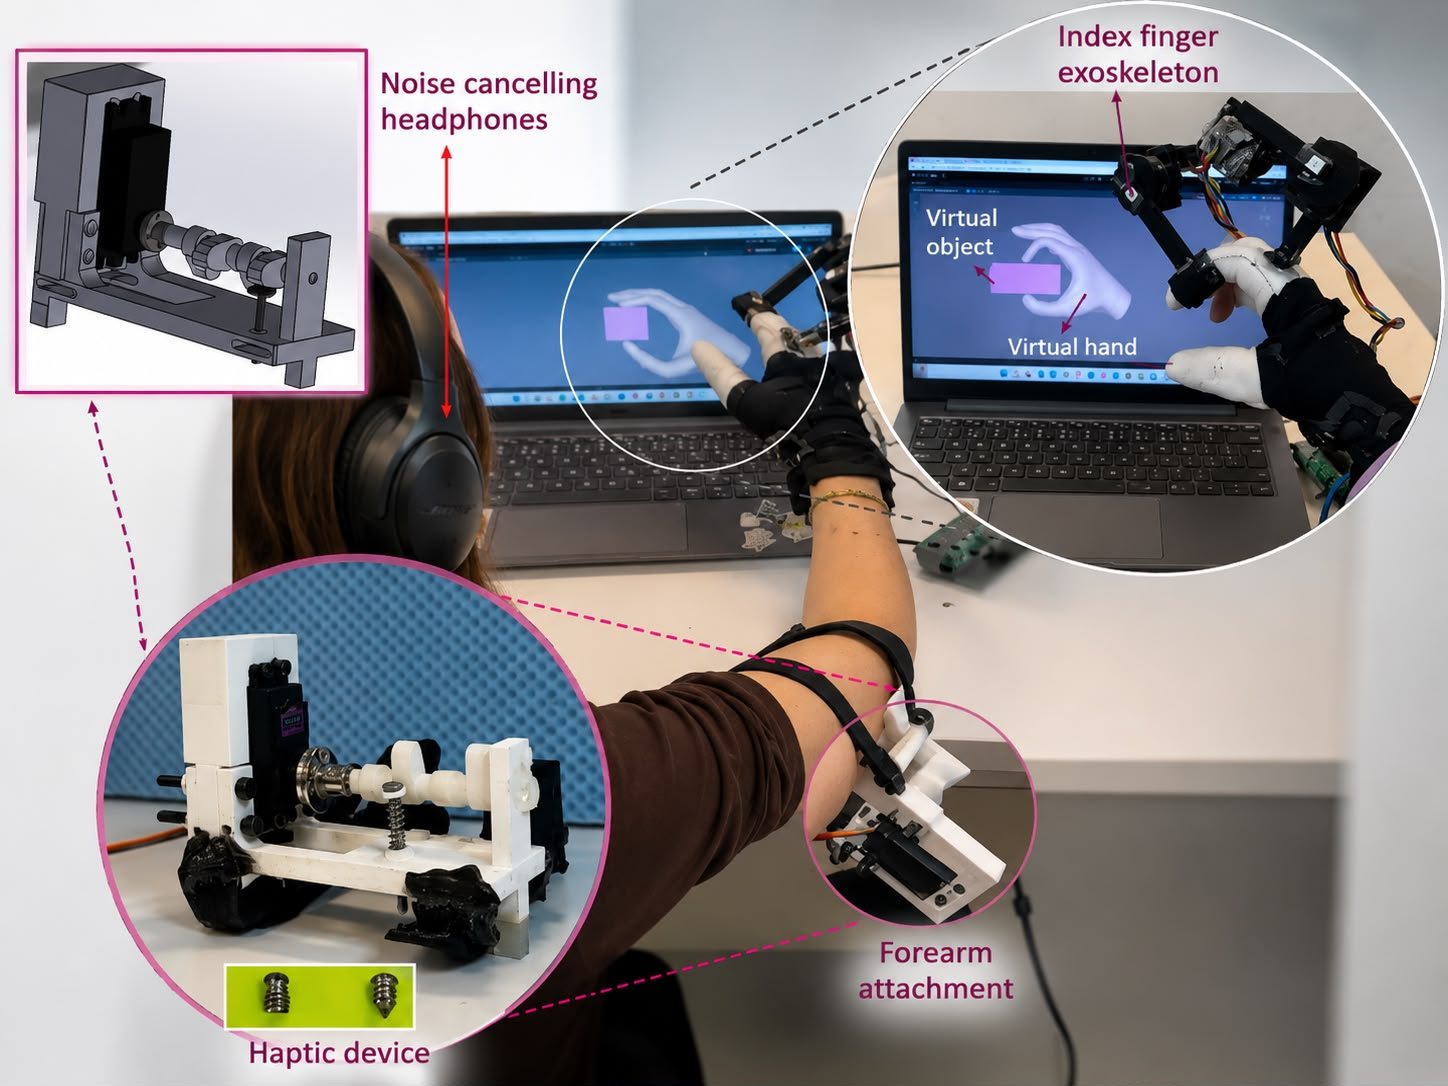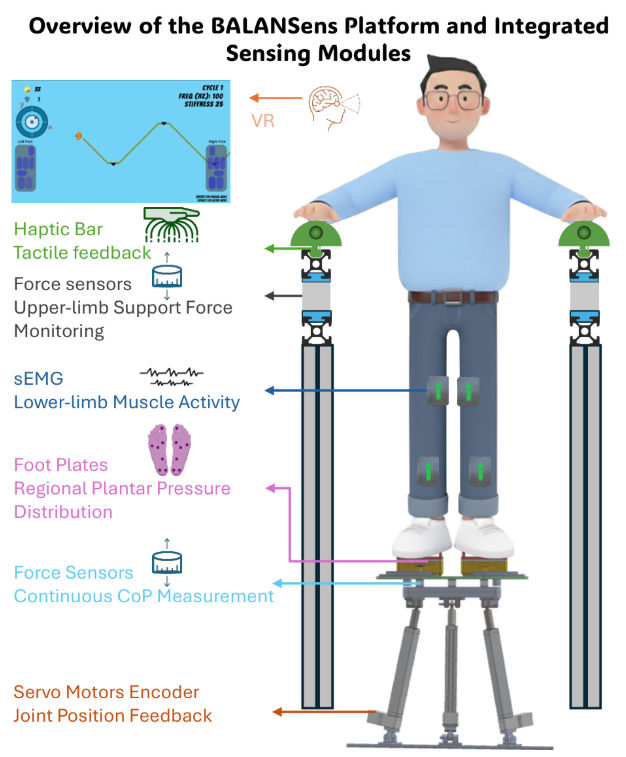
An interface that only reads the person is half an interface. Intention has to be detected, and the consequence of acting on it has to be returned as force, as vibration, as touch. Otherwise the person is operating the device blind.
Research topics
- Human-intention and motor-state sensing
- sEMG-based interfaces
- Sensorimotor interaction
- Haptic and multisensory feedback
- Bidirectional human–robot communication