Active
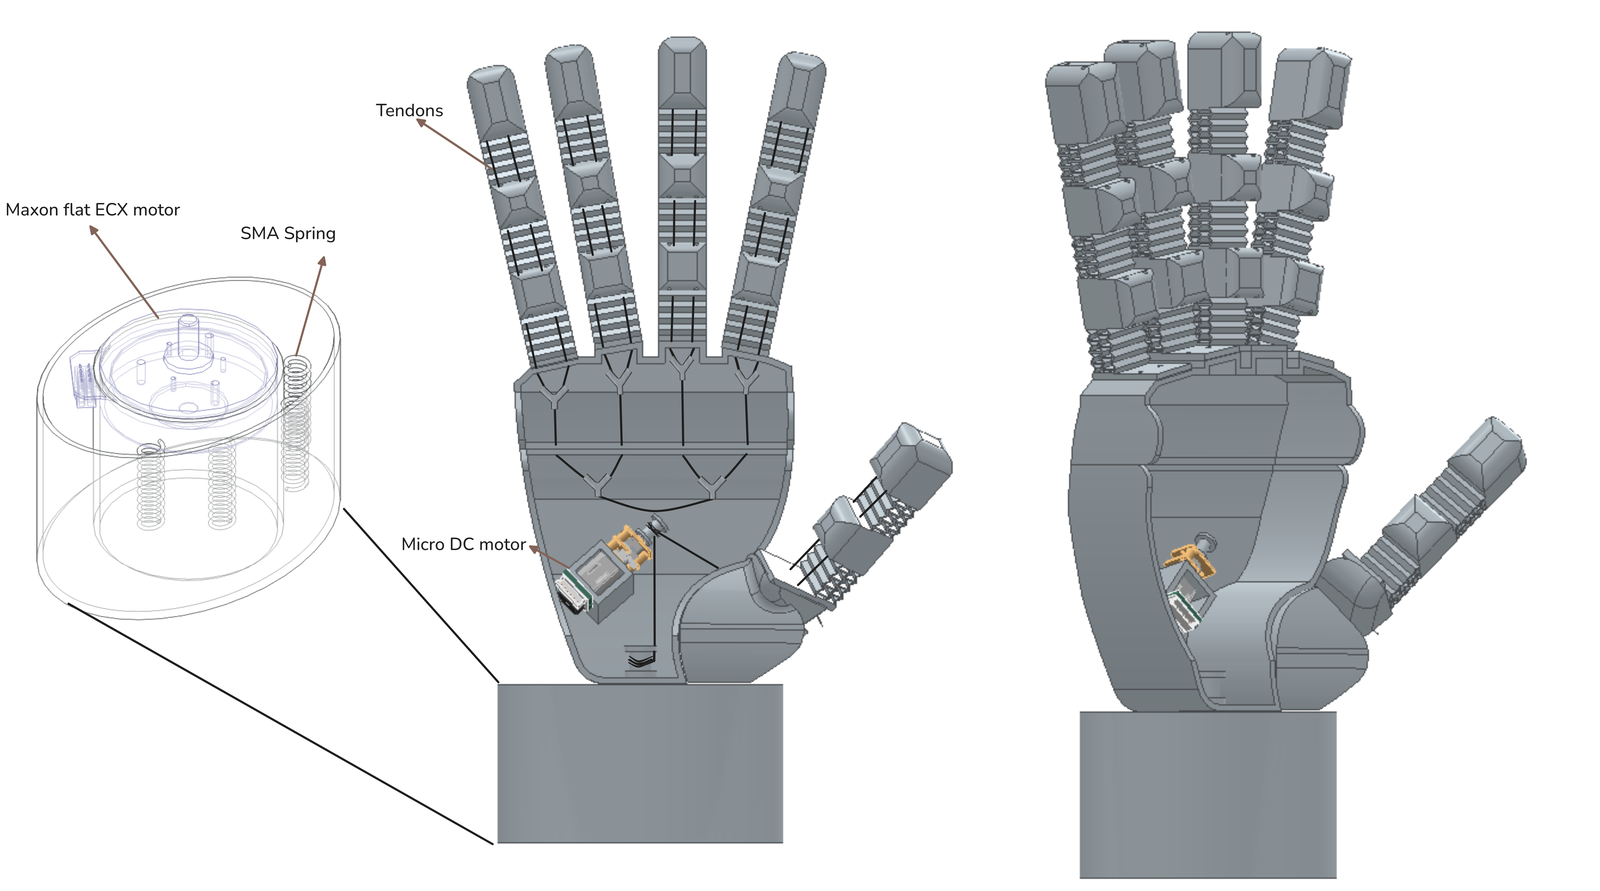
SENSEHand: Adaptive Prosthetic Hand with a Natural Control Interface
An underactuated, variable-stiffness prosthetic hand with sEMG-based control that adapts its grasp the way a human hand does.
We welcome doctoral, MSc and undergraduate researchersOpen positions
Ahlam Sawah is a Biomedical Engineering MSc student and researcher whose work centres on prosthetic robotics and human–machine interfaces, with a focus on variable-stiffness mechanisms and compliant joint design for underactuated prosthetic hands.
She holds a bachelor’s degree in biomedical engineering from Fatih Sultan Mehmet Vakıf University, where she graduated with Honors and ranked third in her class. Her undergraduate work included an EOG-controlled artificial eye that translates natural eye movements into real-time actuation, combining biomedical signal processing with embedded systems. She works across MATLAB, LabVIEW, SolidWorks, ANSYS, Rhino 8 with Grasshopper, and SOFA.
An underactuated, variable-stiffness prosthetic hand with sEMG-based control that adapts its grasp the way a human hand does.