Active
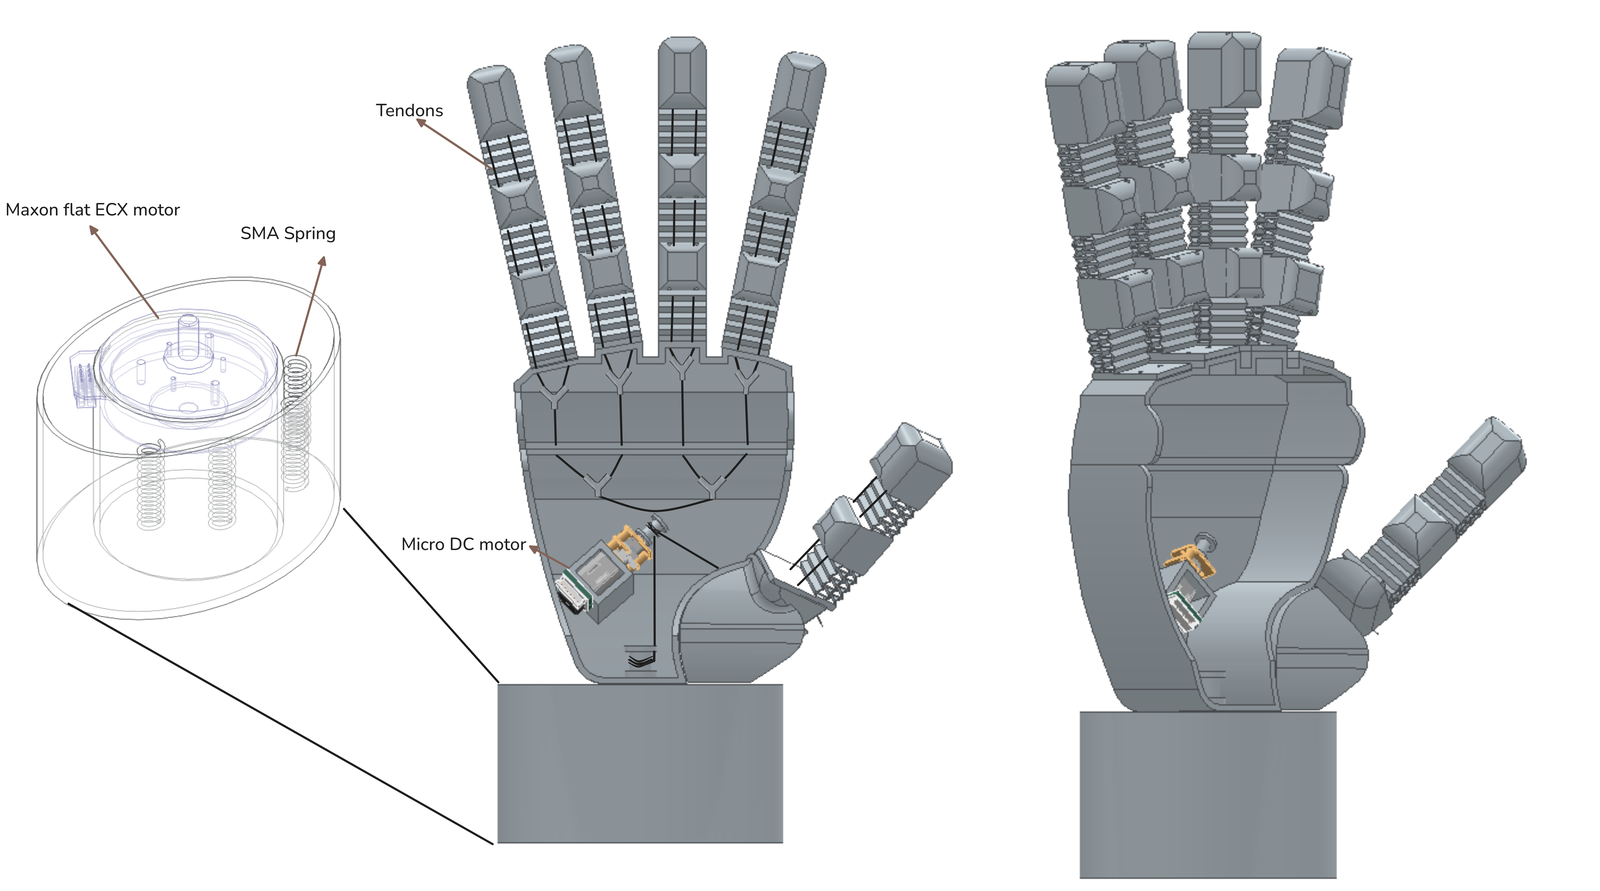
SENSEHand: Adaptive Prosthetic Hand with a Natural Control Interface
An underactuated, variable-stiffness prosthetic hand with sEMG-based control that adapts its grasp the way a human hand does.
We welcome doctoral, MSc and undergraduate researchersOpen positions
Buket Ünal is an M.Sc. researcher in Electrical and Electronics Engineering and Cyber Systems. Her research focuses on sEMG-based human–machine interaction, fingertip stiffness estimation, human hand adaptation, and intuitive and adaptive control approaches for prosthetic hands.
Her current project develops a more intuitive and adaptive control algorithm for prosthetic hands. Rather than relying on predefined commands, discrete grasp selection or repeated mode switching, the study investigates how people naturally adapt their hand and finger behaviour when interacting with different objects and conditions, and transfers that into prosthetic-hand control so that both user intention and changing daily conditions are taken into account.
Finalist, 2023 TEKNOFEST Digital Technologies in Industry Competition. Finalist, 2021 TEKNOFEST Fighting UAV Competition, Rotary Wing Category. Participant and team captain, 2022 TEKNOFEST International UAV Competition.
An underactuated, variable-stiffness prosthetic hand with sEMG-based control that adapts its grasp the way a human hand does.
B. Ünal & E. Hocaoglu
34th Signal Processing and Communications Applications Conference (SIU), pp. 1–4